


R2B2 — Robot autonome ramasseur de balles de tennis
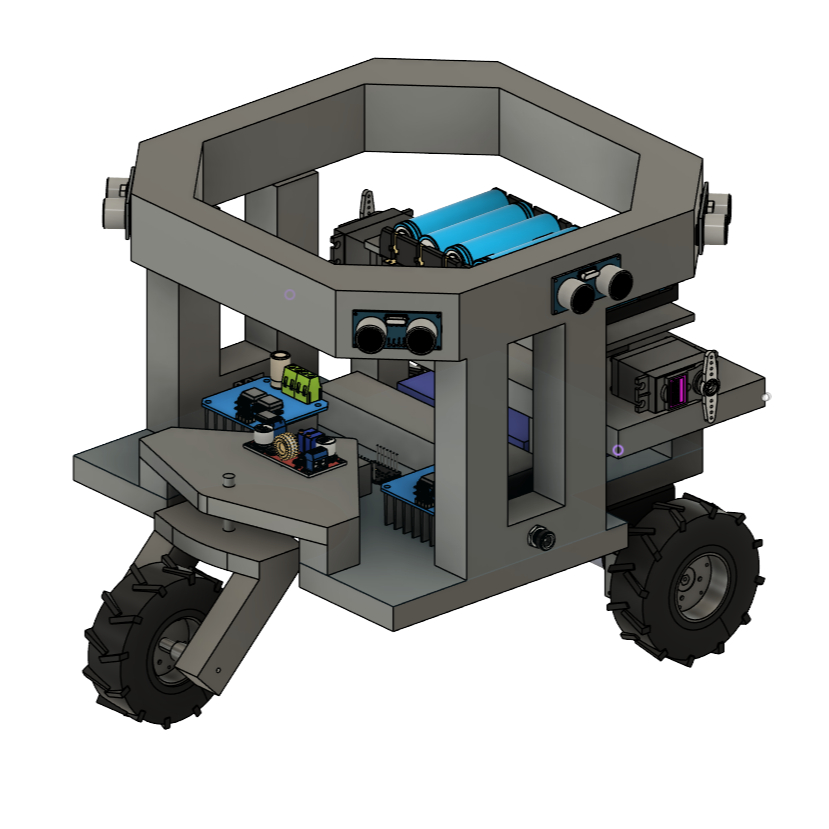
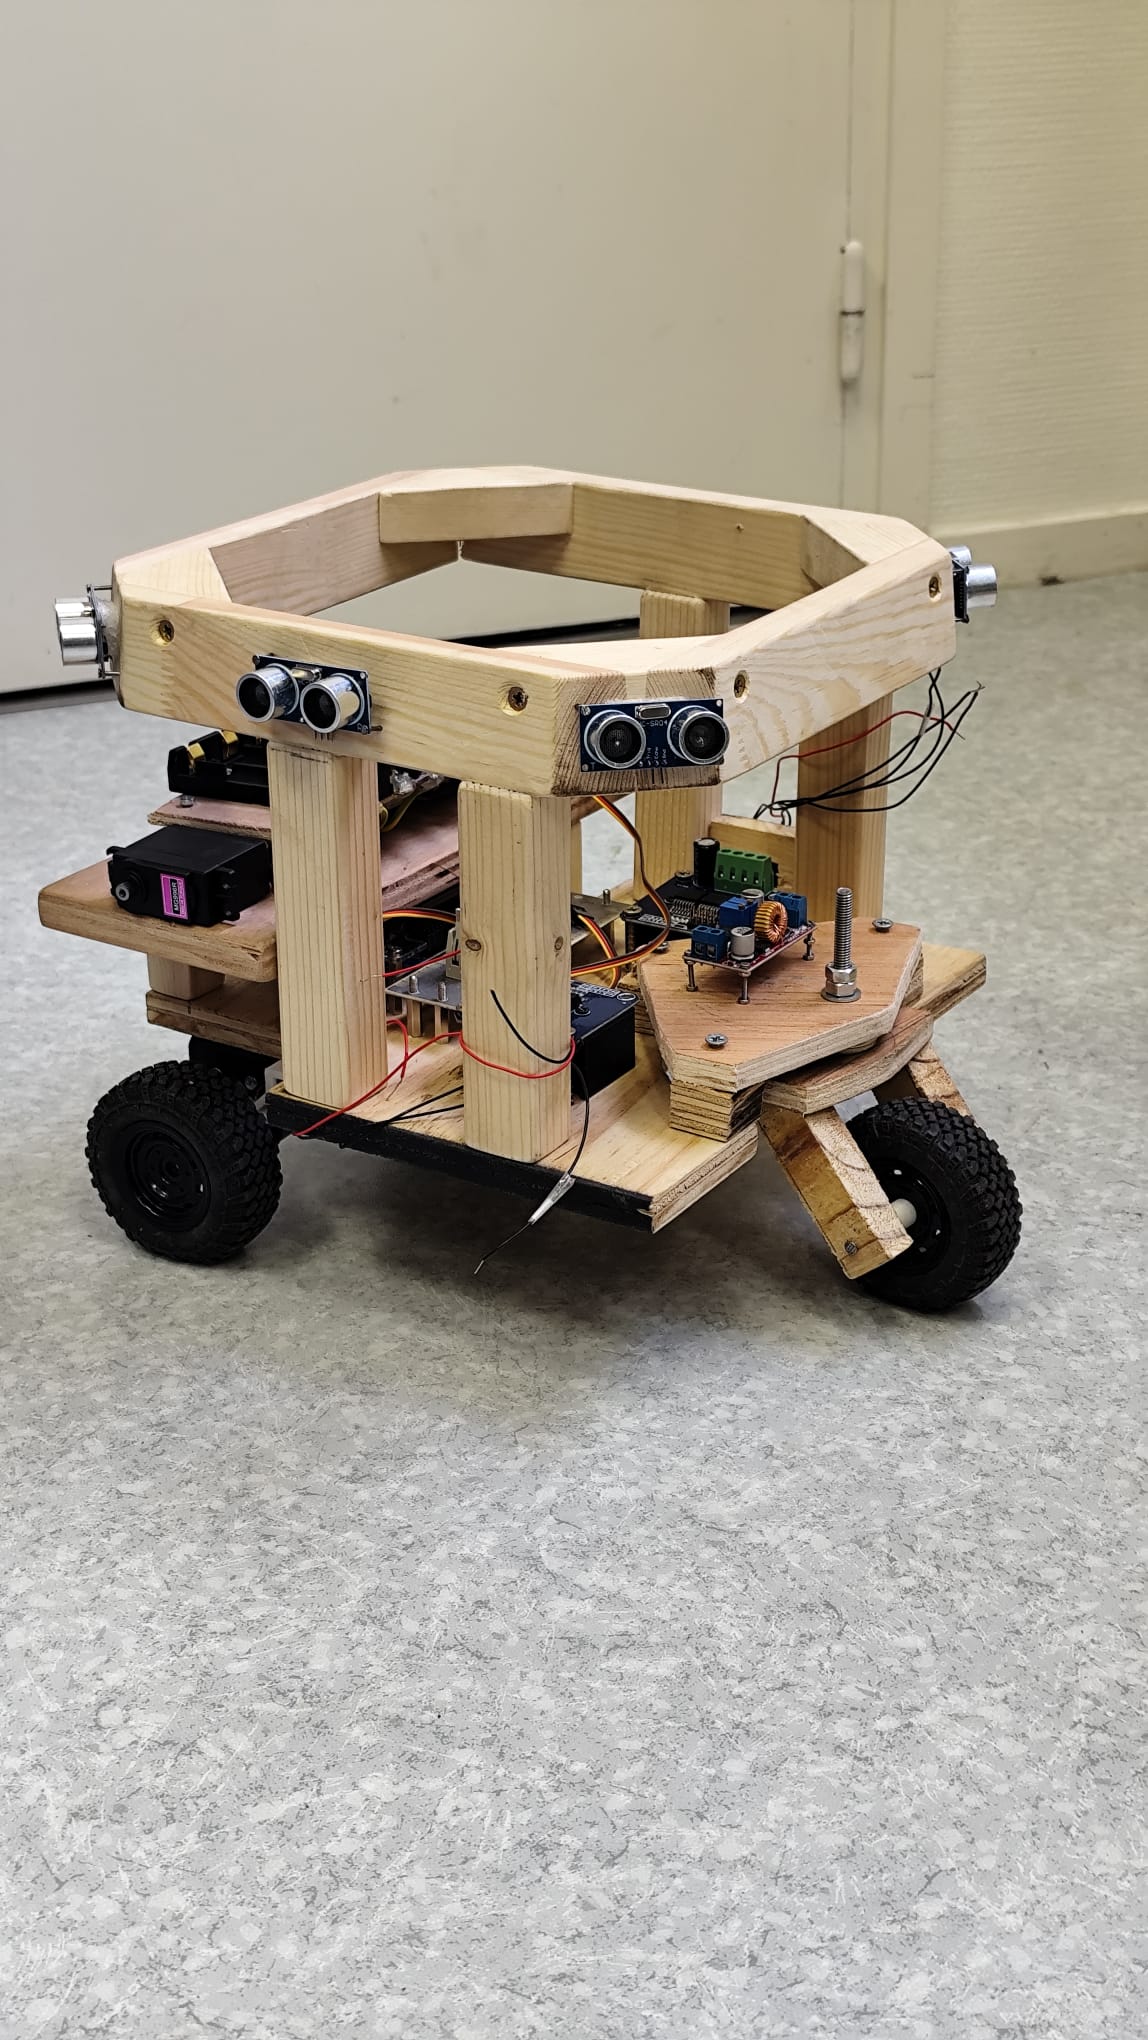
# 1. Clone the repository
git clone https://github.com/NEOWAK/R2B2.git

# See the Development Setup section below.
├── LICENSE
├── docs
│ ├── cdc
│ │ ├── Rapport_CDC.pdf
│ │ └── Rapport_CDC.zip
│ ├── presentation
│ │ ├── R2B2.pdf
│ │ └── R2B2.pptx
│ └── rapport
│ ├── Rapport_PROJET.zip
│ └── Rapport_PROJETELEC_ROBOT_TENNIS.pdf
├── firmware
│ ├── esp32c3
│ │ ├── v0_1.ino.ino
│ │ └── v0_2.ino.ino
│ └── fpga
│ ├── driver
│ │ └── Motor_Controller.vhd
│ ├── pid
│ │ ├── adc0
│ │ │ ├── adc0.bsf
│ │ │ ├── adc0.cmp
│ │ │ ├── adc0.html
│ │ │ ├── adc0.ppf
│ │ │ ├── adc0.xml
│ │ │ ├── adc0_bb.v
│ │ │ ├── adc0_generation.rpt
│ │ │ ├── adc0_inst.v
│ │ │ ├── adc0_inst.vhd
│ │ │ └── synthesis
│ │ │ └── ...
│ │ ├── adc0.qsys
│ │ ├── adc0.sopcinfo
│ │ ├── adc_period.vhd
│ │ ├── baud_gen.vhd
│ │ ├── motor_controller.vhd
│ │ ├── top.vhd
│ │ ├── uart_framer.vhd
│ │ ├── uart_mux.vhd
│ │ ├── uart_rx.vhd
│ │ ├── uart_tx.vhd
│ │ ├── xor.qpf
│ │ ├── xor.qsf
│ │ ├── xor.qws
│ │ └── xor_assignment_defaults.qdf
│ ├── pince
│ │ └── pince_controlleur.vhd
│ └── ultrason
│ └── ultrason.vhd
├── hardware
│ ├── alimentation
│ │ ├── alimentation_0.heic
│ │ └── alimentation_1.heic
│ ├── cao
│ │ ├── pince.f3z
│ │ └── robot.f3z
│ └── pcb
│ ├── pads_layout.pdf
│ ├── pads_logic.pdf
│ ├── pcb.cir
│ ├── pcb.sch
│ ├── pcb_v1.pcb
│ └── pcb_v2.pcb
├── scripts
│ └── courbe_paramétrique.ggb
├── software
│ ├── dashbord
│ │ ├── Capture d’écran du 2026-05-18 06-51-23.png
│ │ └── dashboard.py
│ ├── detection
│ │ ├── esp32_camera.ino
│ │ └── modele_ia.zip
│ └── monitor
│ ├── img
│ │ ├── adc_mesure_5V.png
│ │ ├── adc_mesure_paliers.png
│ │ └── oscilo_mesure_5V.BMP
│ ├── monitor.py
│ └── monitor_v2.py
└── structure
├── pince
│ ├── Capture d’écran du 2026-05-18 06-07-12.png
│ ├── Capture d’écran du 2026-05-18 06-07-25.png
│ ├── Capture d’écran du 2026-05-18 06-07-59.png
│ ├── Capture d’écran du 2026-05-18 06-08-07.png
│ ├── pince3D_01_square.jpg
│ └── pinceo.jpg
└── robot
├── robot_0.jpeg
├── robot_1.jpeg
├── robot_2.jpeg
├── robot_3.jpeg
└── robot_v1.0_img0.jpg
Thanks to everyone who has contributed to this project:

See the full list of contributors →
Contributions are welcome! Here's the standard flow:
- Fork the repository
- Clone your fork:
git clone https://github.com/NEOWAK/R2B2.git - Branch:
git checkout -b feature/your-feature - Commit:
git commit -m 'feat: add some feature' - Push:
git push origin feature/your-feature - Open a pull request
Please follow the existing code style and include tests for new behavior where applicable.
This project is licensed under the MIT License.